
Industrial Robot Clocking: Why MEMS Timing Beats Quartz
發表時間: 2026-10-21 10:37:41
Inside a working cell, an industrial robot never stands still. It holds position and executes millions of motion cycles while continuous vibration, temperature swings and electrical noise act on every control board. The clock IC is one of the smallest parts in the cabinet — and one of the few whose drift shows up everywhere at once: multi-axis synchronization errors, dropped packets on the industrial Ethernet bus, latency in vision feedback, and a slow loss of positioning accuracy.
This article explains why robot clock trees are migrating from quartz crystals to SiTime MEMS timing. It compares the two technologies on the four metrics that matter most on a factory floor — vibration, temperature, power-supply noise and long-term aging — and shows how a three-chip MEMS clock tree can cover the timing needs of an entire industrial robot.
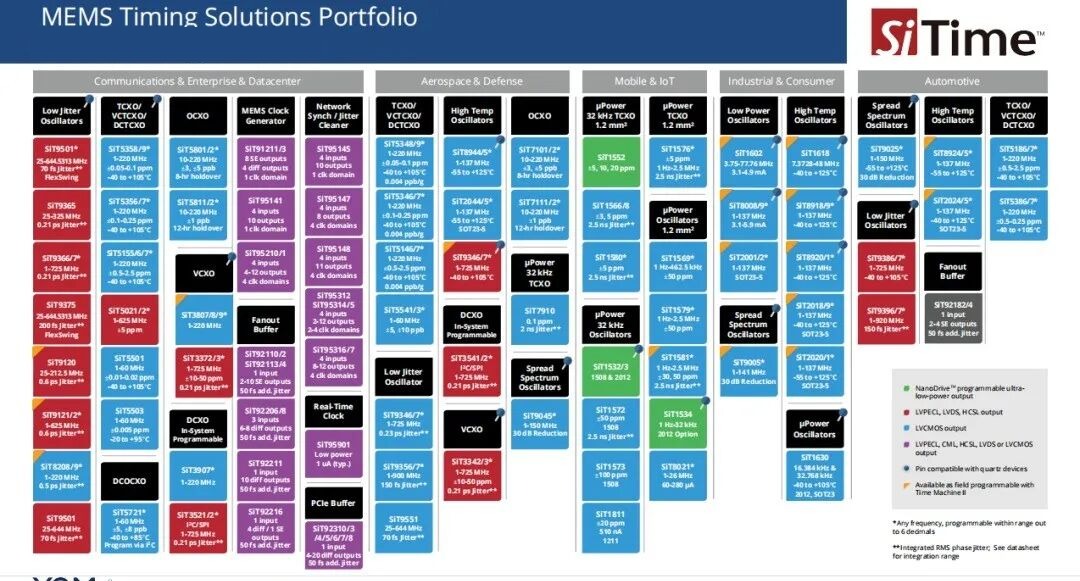
Figure 1: SiTime MEMS timing portfolio — communications, aerospace & defense, mobile & IoT, industrial & consumer, and automotive families, including the Super-TCXO, differential XO and high-temperature XO devices used in robot clock trees. (Image source: SiTime)
1. What an Industrial Robot Clock Tree Has to Survive
A robot controller typically needs clocks at three levels:
- Industrial Ethernet synchronization: EtherCAT and PROFINET buses require microsecond-level synchronization, anchored to an IEEE 1588 PTP reference clock. Its accuracy directly limits how tightly multiple axes can coordinate.
- Main control: the SoC or FPGA reference clock must combine low jitter with immunity to supply noise; otherwise image processing and motion-control loops lose margin.
- Peripheral interfaces: Ethernet PHYs, vision sensors and Wi-Fi modules each require their own clock, distributed across the machine where temperatures differ significantly.
Those layers operate under conditions that are anything but friendly:
- Continuous arm vibration — typically above 20 g, with shock loads reaching several thousand kgf
- Cabinet temperatures from −40 °C up to 105 °C, sometimes 125 °C
- Severe ripple and EMI generated by servo drives
- 8–15 years of continuous, maintenance-free operation
A quartz crystal is a mechanical resonator: vibration shifts its frequency, aging moves it over the years, and start-up behavior changes with temperature. Those are exactly the weaknesses that push robot designs toward MEMS.
2. The SiTime Three-Chip Robot Clock Tree
For industrial robots, SiTime's timing solution comes down to three devices:
| Device | Type | Where it sits in the robot | Key parameters |
|---|---|---|---|
| SiT535x | Super-TCXO | IEEE 1588 PTP reference clock | 1–220 MHz, ±100 ppb, ±1 ppb/°C, 105 °C |
| SiT9375 | Differential XO | SoC/FPGA main reference clock | 25–644 MHz, 0.2 ps RMS jitter, 105 °C |
| SiT891x | High-temperature XO | Ethernet PHY / vision / Wi-Fi | 1–137 MHz, ±20 ppm, 125 °C |
A typical architecture looks like this:
- SiT5356/57 (optional) — a 25 MHz TCXO acting as the local time base for IEEE 1588, keeping axes synchronized to the microsecond
- SiT9375 — a 156.25 MHz differential clock for the SoC/FPGA, the heartbeat of the main controller
- SiT8918 — clocks for the Ethernet module (125 MHz) and the vision sensor (27 MHz)
- Wi-Fi modules can still use an ordinary crystal, although SiTime offers alternatives that drop in directly
Each device is a complete single-chip oscillator. There are no external load capacitors and no matching network to tune — the part goes onto the PCB and works.
3. Four Hard Metrics That Favor MEMS
3.1 Vibration: 70 g Against 20 g
An arm in motion vibrates continuously. Quartz units start to shift frequency — or stop oscillating altogether — above roughly 20 g. A SiTime MEMS resonator is more than 1,000 times lighter than a quartz blank, and its vibration tolerance reaches 70 g, 3.5× that of quartz. Shock tolerance climbs to 30,000 g, compared with about 1,500 g for ordinary quartz. In a collision or an emergency stop, that gap decides whether the clock survives.
3.2 Temperature: What ±100 ppb Buys You
Cabinet temperature swings from a cold winter start to a fully loaded summer shift. The SiT5356/57 Super-TCXO holds ±100 ppb (±0.1 ppm) from −40 °C to 105 °C, with a temperature slope of only ±1 ppb/°C. The IEEE 1588 reference barely moves — and multi-axis synchronization accuracy does not degrade as the cabinet heats up.
3.3 Power-Supply Noise: PSNR Sets the Limit
Servo drives and high-power supplies share the same cabinet, so ripple on the rails is severe. A clock that is sensitive to supply noise converts that ripple into jitter. Under injected noise from 20 kHz to 20 MHz, SiTime differential oscillators (SiT9375/9376/9377) keep jitter growth below 0.08 ps/mV, while ordinary quartz differential oscillators exceed 0.35 ps/mV — nearly 5× worse. That number determines how clean the main controller's clock stays in a real industrial power environment.
3.4 Long-Term Aging: Two Decades Without Recalibration
Industrial robots are specified for 8–15 years of maintenance-free operation. Extrapolated from 105 °C aging data, SiTime Elite-series parts remain in the tens-of-ppb range over 20 years. A quartz TCXO typically ages 1–2 ppm per year — within a few years the accumulated drift exceeds PTP synchronization budgets and requires on-site recalibration.
Reliability at a glance:
- Failure rate: SiTime<2 DPPM vs quartz ≈50 DPPM
- Field failures: SiTime<1 per="" million="" vs="" quartz="">30 per million
- Vibration: 70 g vs 20 g
- Shock: 30,000 g vs 1,500 g
4. Programmability: One Part Number, Many Frequencies
Robot projects change frequency requirements between prototype and volume production. A quartz design needs a different crystal cut for every frequency — long lead times, and a BOM full of separate part numbers.
SiTime oscillators are programmable. A single device can be configured to any frequency from 1 Hz to 725 MHz, with stability from ±0.005 ppm to ±50 ppm across 18 grades, supply voltage from 1.2 V to 3.3 V, and operating temperature from −55 °C to 125 °C — plus adjustable spread spectrum, VC pull range and slew rate. The combinations run into the millions.
For a hardware team, that translates into:
- Any-frequency samples within 48 hours during prototyping
- 6-week production lead times — more than twice as fast as quartz
- One part number serving multiple projects and peripherals, simplifying the BOM
- In-line programming (Through-Machine II): change frequency without re-stocking parts
5. Selection Guide: Where MEMS Pays Off
| Use case | Recommended device | Why |
|---|---|---|
| Industrial Ethernet master/slave PTP clock | SiT535x Super-TCXO | ±100 ppb stability, IEEE 1588 compliance |
| SoC/FPGA main reference clock | SiT9375 differential XO | 0.2 ps low jitter, supply-noise immunity |
| Servo drive / inverter | SiT891x high-temperature XO | 125 °C operation, ±20 ppm |
| Vision / camera module | SiT891x or SiT9365 series | Low jitter, vibration resistance |
| General sensor interface | SiT1602 low-power XO | 3.1–4.9 mA supply current |
6. Conclusion: Field Failures Cost More Than the Chip
If your robot platform still clocks multi-axis synchronization or vision processing with quartz, a MEMS evaluation is worth the effort. The argument is not that MEMS is expensive — it is that a single field failure costs far more than the difference in unit price.
YQM ELECTRONICS is an authorized distributor for the SiTime MEMS timing portfolio, supporting industrial robot designs with SiT535x Super-TCXOs, SiT9375 differential oscillators and SiT891x high-temperature oscillators — from sample requests through volume supply. Explore the SiTime MEMS portfolio, or browse differential oscillators and high-temperature oscillators to select the right device for your robot design.
Request SiTime MEMS Samples & a Clock-Tree Review
●Free sample request
●Clock-tree design support
●Pin-to-pin quartz replacement options
●Volume pricing & lead-time confirmation
Industrial Robot Clocking: Why MEMS Timing Beats Quartz
發表時間: 2026-10-21 10:37:41
Inside a working cell, an industrial robot never stands still. It holds position and executes millions of motion cycles while continuous vibration, temperature swings and electrical noise act on every control board. The clock IC is one of the smallest parts in the cabinet — and one of the few whose drift shows up everywhere at once: multi-axis synchronization errors, dropped packets on the industrial Ethernet bus, latency in vision feedback, and a slow loss of positioning accuracy.
This article explains why robot clock trees are migrating from quartz crystals to SiTime MEMS timing. It compares the two technologies on the four metrics that matter most on a factory floor — vibration, temperature, power-supply noise and long-term aging — and shows how a three-chip MEMS clock tree can cover the timing needs of an entire industrial robot.
Figure 1: SiTime MEMS timing portfolio — communications, aerospace & defense, mobile & IoT, industrial & consumer, and automotive families, including the Super-TCXO, differential XO and high-temperature XO devices used in robot clock trees. (Image source: SiTime)
1. What an Industrial Robot Clock Tree Has to Survive
A robot controller typically needs clocks at three levels:
- Industrial Ethernet synchronization: EtherCAT and PROFINET buses require microsecond-level synchronization, anchored to an IEEE 1588 PTP reference clock. Its accuracy directly limits how tightly multiple axes can coordinate.
- Main control: the SoC or FPGA reference clock must combine low jitter with immunity to supply noise; otherwise image processing and motion-control loops lose margin.
- Peripheral interfaces: Ethernet PHYs, vision sensors and Wi-Fi modules each require their own clock, distributed across the machine where temperatures differ significantly.
Those layers operate under conditions that are anything but friendly:
- Continuous arm vibration — typically above 20 g, with shock loads reaching several thousand kgf
- Cabinet temperatures from −40 °C up to 105 °C, sometimes 125 °C
- Severe ripple and EMI generated by servo drives
- 8–15 years of continuous, maintenance-free operation
A quartz crystal is a mechanical resonator: vibration shifts its frequency, aging moves it over the years, and start-up behavior changes with temperature. Those are exactly the weaknesses that push robot designs toward MEMS.
2. The SiTime Three-Chip Robot Clock Tree
For industrial robots, SiTime's timing solution comes down to three devices:
| Device | Type | Where it sits in the robot | Key parameters |
|---|---|---|---|
| SiT535x | Super-TCXO | IEEE 1588 PTP reference clock | 1–220 MHz, ±100 ppb, ±1 ppb/°C, 105 °C |
| SiT9375 | Differential XO | SoC/FPGA main reference clock | 25–644 MHz, 0.2 ps RMS jitter, 105 °C |
| SiT891x | High-temperature XO | Ethernet PHY / vision / Wi-Fi | 1–137 MHz, ±20 ppm, 125 °C |
A typical architecture looks like this:
- SiT5356/57 (optional) — a 25 MHz TCXO acting as the local time base for IEEE 1588, keeping axes synchronized to the microsecond
- SiT9375 — a 156.25 MHz differential clock for the SoC/FPGA, the heartbeat of the main controller
- SiT8918 — clocks for the Ethernet module (125 MHz) and the vision sensor (27 MHz)
- Wi-Fi modules can still use an ordinary crystal, although SiTime offers alternatives that drop in directly
Each device is a complete single-chip oscillator. There are no external load capacitors and no matching network to tune — the part goes onto the PCB and works.
3. Four Hard Metrics That Favor MEMS
3.1 Vibration: 70 g Against 20 g
An arm in motion vibrates continuously. Quartz units start to shift frequency — or stop oscillating altogether — above roughly 20 g. A SiTime MEMS resonator is more than 1,000 times lighter than a quartz blank, and its vibration tolerance reaches 70 g, 3.5× that of quartz. Shock tolerance climbs to 30,000 g, compared with about 1,500 g for ordinary quartz. In a collision or an emergency stop, that gap decides whether the clock survives.
3.2 Temperature: What ±100 ppb Buys You
Cabinet temperature swings from a cold winter start to a fully loaded summer shift. The SiT5356/57 Super-TCXO holds ±100 ppb (±0.1 ppm) from −40 °C to 105 °C, with a temperature slope of only ±1 ppb/°C. The IEEE 1588 reference barely moves — and multi-axis synchronization accuracy does not degrade as the cabinet heats up.
3.3 Power-Supply Noise: PSNR Sets the Limit
Servo drives and high-power supplies share the same cabinet, so ripple on the rails is severe. A clock that is sensitive to supply noise converts that ripple into jitter. Under injected noise from 20 kHz to 20 MHz, SiTime differential oscillators (SiT9375/9376/9377) keep jitter growth below 0.08 ps/mV, while ordinary quartz differential oscillators exceed 0.35 ps/mV — nearly 5× worse. That number determines how clean the main controller's clock stays in a real industrial power environment.
3.4 Long-Term Aging: Two Decades Without Recalibration
Industrial robots are specified for 8–15 years of maintenance-free operation. Extrapolated from 105 °C aging data, SiTime Elite-series parts remain in the tens-of-ppb range over 20 years. A quartz TCXO typically ages 1–2 ppm per year — within a few years the accumulated drift exceeds PTP synchronization budgets and requires on-site recalibration.
Reliability at a glance:
- Failure rate: SiTime<2 DPPM vs quartz ≈50 DPPM
- Field failures: SiTime<1 per="" million="" vs="" quartz="">30 per million
- Vibration: 70 g vs 20 g
- Shock: 30,000 g vs 1,500 g
4. Programmability: One Part Number, Many Frequencies
Robot projects change frequency requirements between prototype and volume production. A quartz design needs a different crystal cut for every frequency — long lead times, and a BOM full of separate part numbers.
SiTime oscillators are programmable. A single device can be configured to any frequency from 1 Hz to 725 MHz, with stability from ±0.005 ppm to ±50 ppm across 18 grades, supply voltage from 1.2 V to 3.3 V, and operating temperature from −55 °C to 125 °C — plus adjustable spread spectrum, VC pull range and slew rate. The combinations run into the millions.
For a hardware team, that translates into:
- Any-frequency samples within 48 hours during prototyping
- 6-week production lead times — more than twice as fast as quartz
- One part number serving multiple projects and peripherals, simplifying the BOM
- In-line programming (Through-Machine II): change frequency without re-stocking parts
5. Selection Guide: Where MEMS Pays Off
| Use case | Recommended device | Why |
|---|---|---|
| Industrial Ethernet master/slave PTP clock | SiT535x Super-TCXO | ±100 ppb stability, IEEE 1588 compliance |
| SoC/FPGA main reference clock | SiT9375 differential XO | 0.2 ps low jitter, supply-noise immunity |
| Servo drive / inverter | SiT891x high-temperature XO | 125 °C operation, ±20 ppm |
| Vision / camera module | SiT891x or SiT9365 series | Low jitter, vibration resistance |
| General sensor interface | SiT1602 low-power XO | 3.1–4.9 mA supply current |
6. Conclusion: Field Failures Cost More Than the Chip
If your robot platform still clocks multi-axis synchronization or vision processing with quartz, a MEMS evaluation is worth the effort. The argument is not that MEMS is expensive — it is that a single field failure costs far more than the difference in unit price.
YQM ELECTRONICS is an authorized distributor for the SiTime MEMS timing portfolio, supporting industrial robot designs with SiT535x Super-TCXOs, SiT9375 differential oscillators and SiT891x high-temperature oscillators — from sample requests through volume supply. Explore the SiTime MEMS portfolio, or browse differential oscillators and high-temperature oscillators to select the right device for your robot design.
Request SiTime MEMS Samples & a Clock-Tree Review
●Free sample request
●Clock-tree design support
●Pin-to-pin quartz replacement options
●Volume pricing & lead-time confirmation
Other Articles
-

SGT MOSFET for Robotics: Joint Motor Drive & Battery Protection
-
YQ8563: Drop-In Low-Power RTC Replacement for NXP PCF8563
-
Industrial Robot Clocking: Why MEMS Timing Beats Quartz
-
YQ8025T RTC: Built-in DTCXO, No Crystal — RX8025T Alternative
-
Sunlord WL-FS Wire-Wound Ferrite Inductors for Audio Lines: Purer Sound, Lower THD
-
Epson TSX-3225C Crystal: Pin-to-Pin FA-238 Upgrade for 5G, IoT & Automotive
-
NCE90N800F 900V Super-Junction MOSFET — CoolMOS Alternative
-
SiTime PNT Timing Foundation: Why Precision Oscillators Define Modern Navigation
-
NCE Gen.8 IGBT Series: 1200V/140A NCE140GD120VTP4 Benchmarks Ahead of Top Competitors
-
YXC High-Performance Timing Devices Empowering a New Experience in AI Wearables


Copyright By © YQM ELECTRONICS INTL LIMITED SITEMAP
Email: sales@yqmec.com

點擊右上角
分享給朋友吧


